How Do You Match MBWE Cartesian Robot Payload and Travel to Part Size?
2026/11/04 By le zhan
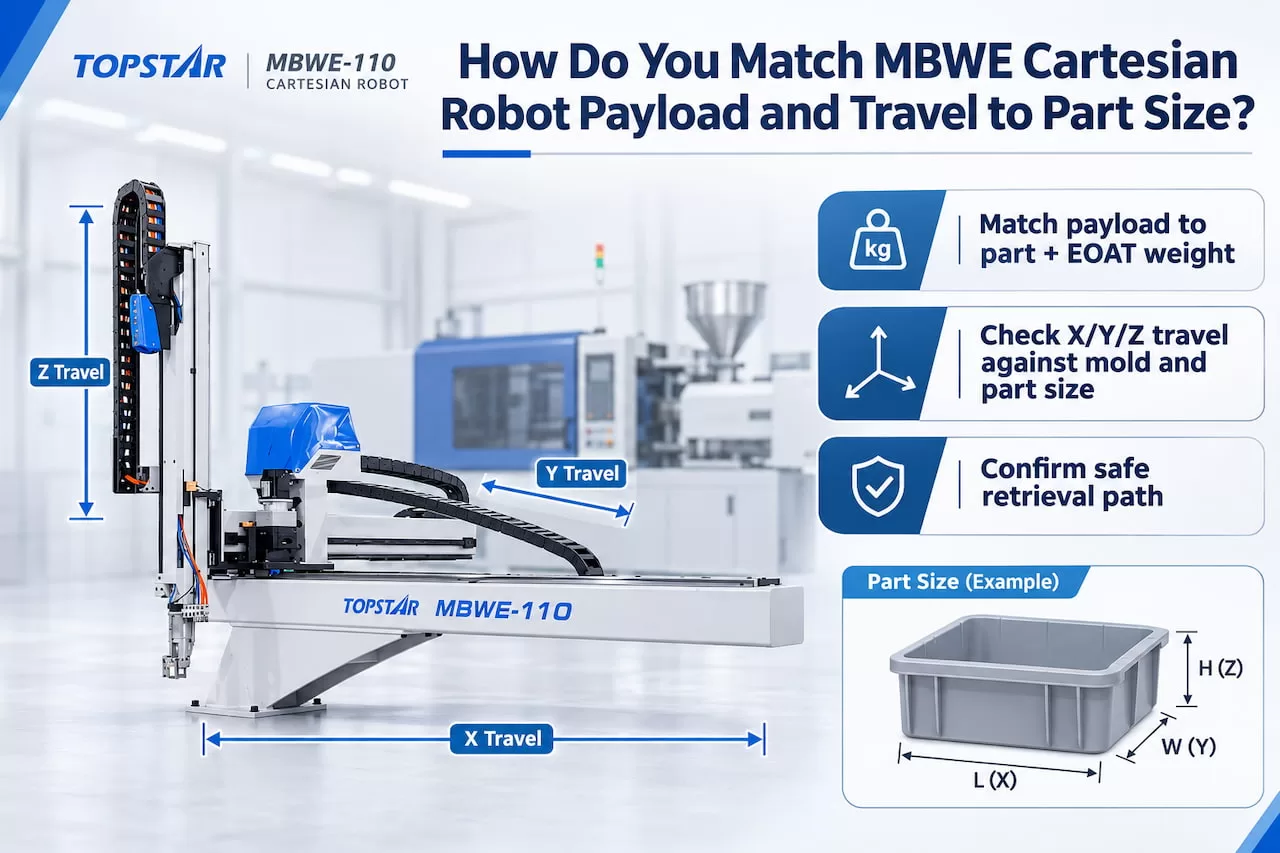
When selecting an MBWE Cartesian robot, match two key specifications to the actual workpiece: payload capacity and arm reach. Larger workpieces may require heavier fixtures and a longer working radius; conversely, workpieces that are both large in volume and heavy may require a higher payload capacity but do not necessarily require an extremely long reach. The MBWE-110V, MBWE-130V, and MBWE-170V models in the MBWE series offer different payload and reach combinations, allowing manufacturers to configure the right heavy-duty take-out robot for various injection molding applications. The final selection will depend on the total weight of the workpiece and fixture, the workpiece dimensions, and the required take-out path.
What are the differences in payload capacity and model specifications among the various MBWE Cartesian robot?
Topstar’s MBWE performance comparison includes three main options: the 110V model for lighter loads, the 130V model for medium-to-heavy workpieces, and the 170V model for large, heavy workpieces. The differences in maximum payload and arm reach among these models can serve as a preliminary reference when selecting the appropriate Cartesian robot; however, the final selection must still be determined based on the actual workpiece and fixture configuration.
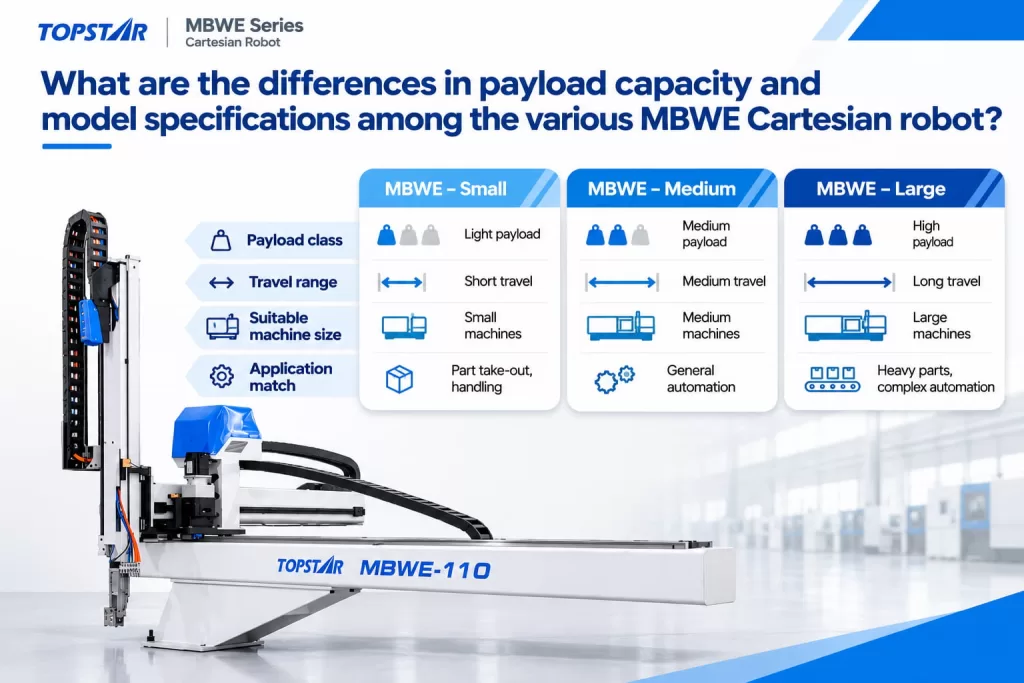
What are the differences in payload and arm reach among the various models?
The specifications for these three configurations are as follows:
| Model | Maximum payload | Arm stroke options | Main-arm fore-and-aft stroke |
|---|---|---|---|
| MBWE-110V | 8 kg | 1200 / 1400 mm | 930 mm |
| MBWE-130V | 15 kg (20 kg configuration) | 1300 / 1500 / 1700 mm | 1000 mm |
| MBWE-170V | 25 kg (30 kg configuration) | 1700 / 2000 / 2300 mm | 1500 mm |
These differences define three practical selection ranges:
- MBWE-110V: Suitable for lighter workpieces and compact retrieval applications, with a maximum payload capacity of 8 kg.
- MBWE-130V: Offers higher payload capacity and longer reach options, suitable for medium- to large-sized products and heavier fixtures.
- MBWE-170V: Designed for heavier workpieces and longer-reach requirements, with payload configurations up to 25 kg or 30 kg.
Arm reach and the main arm’s forward-backward travel are distinct specification parameters. When selecting a model, verify these two parameters based on the actual mold conditions and the robot’s installation layout.
How is the actual payload of an MBWE Cartesian robot calculated?
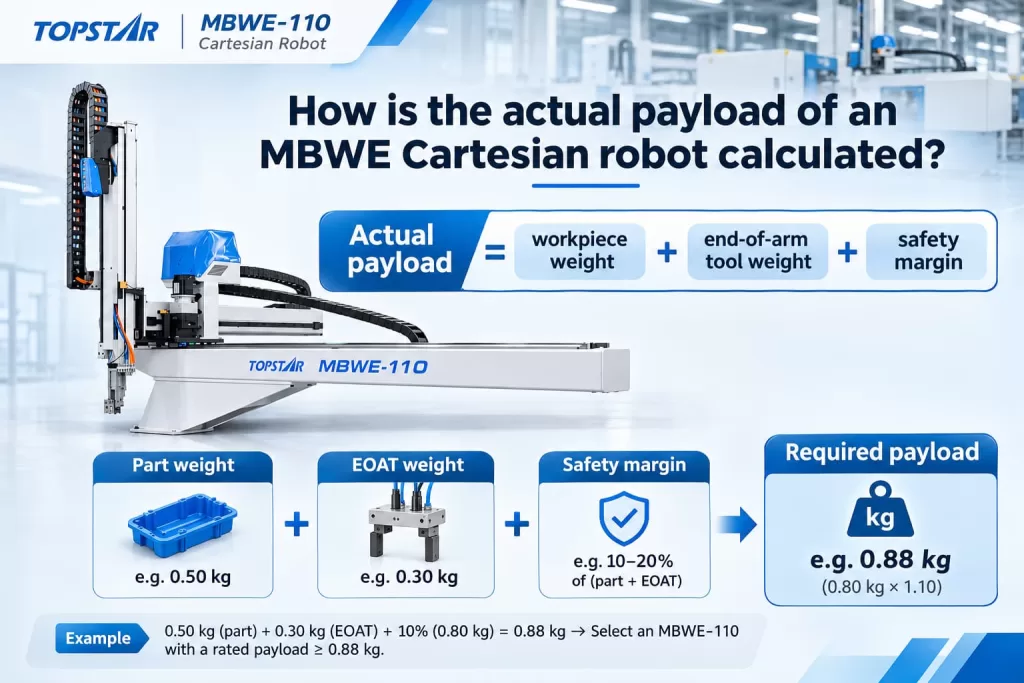
A common misconception among customers during the selection process is to consider only the weight of the molded product. In actual applications, the robot must support the entire end-effector (end-of-arm tooling) assembly.
The calculation of the actual payload should include:
Workpiece weight + tooling weight + mounting plate + suction cup + cylinder + sensors and other components being carried.
For example, if an automotive plastic part weighs 6 kg and its gripper and mounting structure weigh 2 kg, the total load is 8 kg. This already reaches the MBWE-110V’s rated maximum load, leaving no capacity for additional components and preventing it from meeting dynamic operation requirements. In this case, the MBWE-130V would be a better choice.
Engineers should also consider the workpiece’s center of gravity. If the workpiece is long and the gripping point sits away from the robot arm’s center, it generates a greater mechanical load during acceleration and deceleration than a workpiece of the same weight but with a more compact structure.
Therefore, when selecting a load capacity, consider both total mass and load distribution. If the total load is close to the rated capacity, the center of gravity is significantly offset, or the fixture requires a long reach, consider selecting a model with a higher load capacity and verify the allowable load torque.
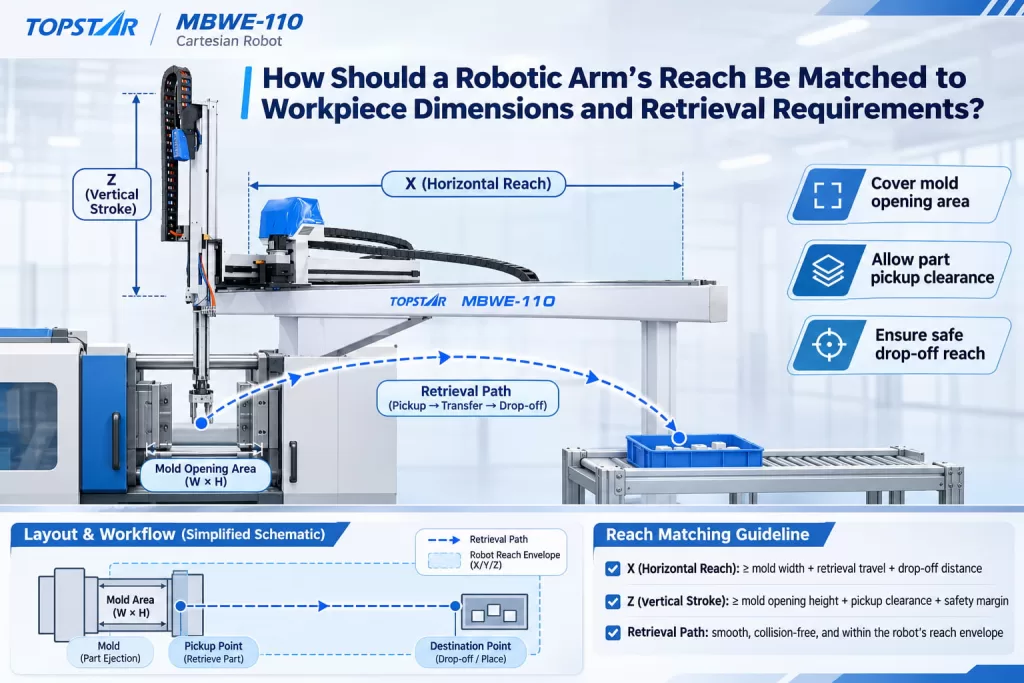
How Should a Robotic Arm’s Reach Be Matched to Workpiece Dimensions and Retrieval Requirements?
Load capacity alone is insufficient to determine whether a robot can perform the required retrieval motion. The robotic arm must reach a specified location within the mold, safely retrieve the product, and transport it to a predetermined placement point or downstream station. For large workpieces, the required range of motion also depends on the mold depth, opening space, product orientation, and fixture dimensions. Therefore, when selecting a robotic arm reach, you cannot simply match it to the physical length of the workpiece; instead, you must evaluate the entire motion path.
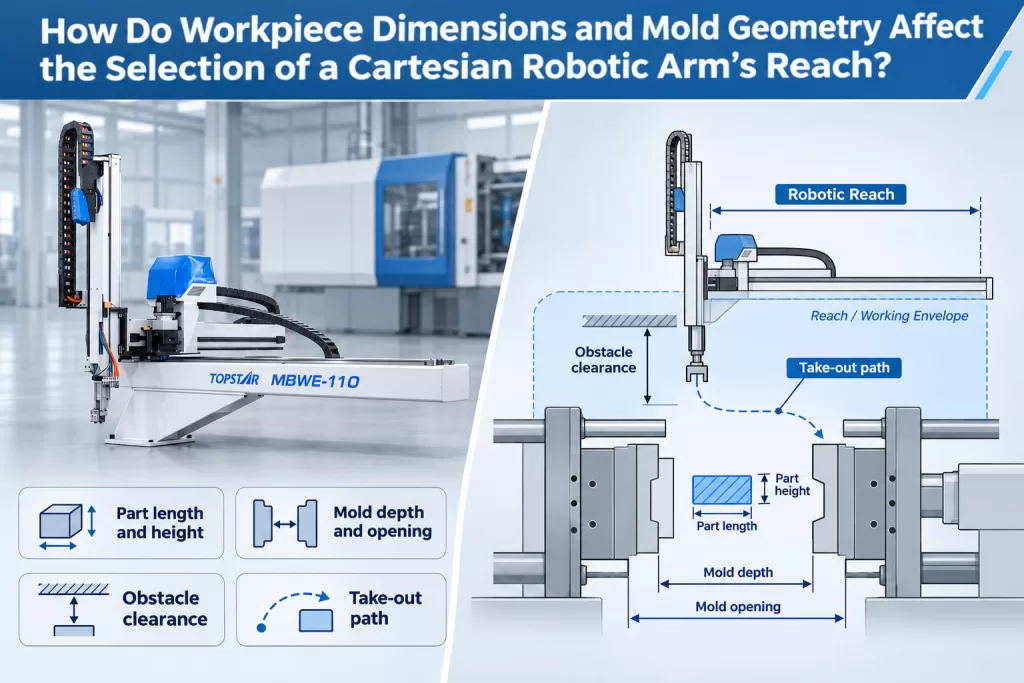
How Do Workpiece Dimensions and Mold Geometry Affect the Selection of a Cartesian Robotic Arm’s Reach?
A longer workpiece does not necessarily require the longest robotic arm reach. The key is whether the pick-and-place robot can reach the gripping position, remove the product from the mold, and complete the motion while avoiding surrounding structures.
Therefore, before determining the reach, evaluate the following three factors:
- Mold depth and removal position: The robotic arm must reach the target position inside the mold and safely remove the workpiece.
- Workpiece Dimensions and Gripper Design: Large or irregularly shaped workpieces may require a longer gripping structure, thereby increasing the required clearance space.
- Conveyance Distance: The robot must reach the designated unloading or placement location. If the required distance exceeds the existing stroke range, reevaluate the installation layout or consider adding extra axes.
For example, a large but lightweight home appliance housing—despite its modest total weight—may require a longer robotic arm reach due to its large dimensions. Conversely, compact metal inserts or heavier plastic parts, while demanding higher payload capacity, may require only a moderate reach.
The MBWE-170V model offers a reach of up to 2300 mm; by comparison, the MBWE-130V has a reach of 1700 mm, while the MBWE-110V has a reach of 1400 mm. This provides greater flexibility for various workshops when handling large products or working with deep mold structures.
When Should You Choose an MBWE Cartesian Robot with a Higher Payload or Longer Stroke Configuration?
When making your final selection, consider the workpiece weight, fixture design, and the entire retrieval path. Please refer to the following practical application scenarios:
Situations where the MBWE-110V is recommended:
- The total load of the workpiece and fixture is within 8 kg, with ample margin.
- A 1200 mm or 1400 mm arm reach is sufficient to access the mold and retrieve the workpiece.
- The application involves relatively compact product dimensions, and the retrieval motion is relatively simple.
When to choose the MBWE-130V:
- The application requires a load capacity above the 110V configuration limit.
- The workpiece or fixture requires a longer arm reach.
- Stroke options of 1300 mm, 1500 mm, or 1700 mm provide sufficient working range to cover the mold area and subsequent handling layout.
When to choose the MBWE-170V:
- The total payload requirement is 25 kg (or 30 kg with the optional upgrade).
- Workpieces are large, or the fixture structure is long, requiring a longer travel range.
- The application requires a 1700 mm, 2000 mm, or 2300 mm arm reach, as well as a 1500 mm main arm fore-and-aft travel.
If the workpiece has an offset center of gravity, the fixture adds significant weight, or the operation requires high-intensity acceleration and deceleration, consider a model with a higher load capacity.
Making the Final Selection
Before selecting the MBWE injection molding robot model, verify the entire handling process under actual operating conditions, including entering the mold, gripping, exiting, leaving the mold area, transporting, and placing. Comprehensively evaluate the payload, stroke, installation space, and required cycle time.
Ultimately, matching the right MBWE Cartesian robot to a workpiece requires two complementary decisions: first, ensuring the payload capacity is sufficient to handle the combined weight of the workpiece and fixture; and second, ensuring the arm’s reach is sufficient to safely complete all required movements. The MBWE-110V, 130V, and 170V models offer different combinations of these capabilities, enabling manufacturers to select a heavy-duty take-out robot based on their actual production needs, rather than simply choosing the model with the highest specifications.
TRENDING POSTS
- TOPS DAY 2026: Turning Industrial AI into Real-World Impact 2026/11/04
- Breaking Through the Full Scene-to-AI Link! Topstar Industrial Data Collection Matrix Achieves Major Technical Breakthro 2026/11/04
- TOPSTAR Selected in “Forbes China AI Top 50” and Wins “2026 Embodied AI Industry Benchmark Award” 2026/11/04
- Topstar Achieves ISO 13849 Functional Safety Certification for Robotics 2026/11/04
HOT TOPIC
- .ervo motor-driven linear robots
- •
- 1.0 guangdong topstar technology co. ltd
- 1.0 topstar china
- 1.0 topstar robot
- 11
- 160℃ mold temperature controller
- 170 ton injection molding machine
- 2
- 21
- 220-ton injection molding machine
- 23
- 260 ton injection molding machine
- 3 axis robot
- 3 axis robots
- 3 in 1 Compact Dehumidifying Dryer
- 3-axis robot
- 3-axis robots
- 39
- 4 axis robot
- 4-axis SCARA robot
- 41
- 460T injection molding machine
- 5-axis CNC machine
- 62
- 90 ton injection molding machine
- accuracy
- Air Chillers
- air-cooled chillers
- all electric injection molding machine
- all electric injection molding machines
- all-electric injection molding machine
- All-electric injection molding machines
- and overall production quality. Therefore
- AP-RubberPlas
- auto cooling system
- auto loader
- Auto Loaders
- automated injection molding machine
- Automation changed engineering
- automation of injection molding robots
- automotive parts injection molding
- Auxiliary Equipment
- auxiliary machine
- Bench Injection Molding Machine
- cabinet dryer
- Cabinet dryer manufacturers
- Cabinet dryers
- cartesian coordinate robot
- Cartesian Coordinate Robots
- Cartesian injection robot
- Cartesian robot
- Central Feeding System
- Central Feeding Systems
- chiller
- CNC Drilling Machine
- CNC Drilling Machines
- cnc engraving machine manufacturer
- cnc laser cutting machine manufacturer
- CNC machine
- CNC Machine Center
- CNC Machine for Sale
- CNC Machine Manufacturing
- CNC Machine Tool
- CNC machine tool product
- CNC Machining Center
- CNC wood carving machine
- Compact Dehumidifying Dryer
- Cooling system
- Cross-Walking Single Axis Servo Cylinder Robot
- Cross-Walking Single-Axis Servo Cylinder Robot
- Cross-Walking Three-Axis/Five-Axis Servo Driven Robot
- cross-walking three-axis/five-axis servo-driven robot
- Dehumidifier Dryer
- Dehumidifying Dryer
- dehumidifying dryers
- delta parallel robot
- Desktop Injection Molding Machine
- Desktop injection molding machines
- Desktop Molding Machine
- desktop plastic injection machine
- Desktop Plastic Injection Molding Machine
- detachable autoloader
- Digital Transformation
- direct clamp injection molding machine
- Direct clamp injection molding machines
- Dosing & mixing system
- Drilling Centers
- Drying and dehumidification system
- drying and dehumidifying equipment
- Drying and Dehumidifying System
- drying system
- effective and efficient. Cabinet dryers are also used in other industries where large quantities of material need to be dried
- efficient injection molding machine
- elbow hydraulic injection molding machines
- electric injection molding machine
- electric injection molding machines
- energy-efficient injection molding robot
- energy-efficient water chiller
- energy-efficient water chillers
- energy-saving injection molding machine
- etc. Among injection molding robots
- exhibition
- features of CNC machine
- Feeding And Conveying System
- Five Axis Machine Center
- Flexible Production Line
- Fully automatic injection molding machine
- Gathering Topstar
- giant injection molding machine
- GMU-600 5-Axis Machining Center
- Granulating & Recycling System
- granulator machine
- gravimetric blender
- Heavy duty injection molding machine
- Heavy-Duty Take-Out Robot
- High-precision electric molding machines
- high-precision plastic molding machines
- high-speed all electric injection molding machine
- high-speed electric injection molding machine
- High-Speed Packaging Injection Molding
- Honeycomb rotor dehumidifier
- hopper dryer
- Hopper Dryers
- horizontal injection molding machine
- Horizontal Injection Molding Machines
- Horizontal Injection Moulding Machine
- Horizontal Mixer manufacturer
- How The CNC Machine Works
- hybrid injection molding machine
- hydraulic injection molding machine
- Hydraulic Injection Molding Machines
- in this article
- Industrial AI
- Industrial Automation
- Industrial robot
- Industrial Robot Chinese brand
- industrial robot parts
- industrial robot supplier
- Industrial robots
- Industry Chain
- Injection Manipulator
- injection manipulator robot
- injection mold machines
- Injection molding
- Injection molding automation
- Injection Molding Automation Solution
- injection molding dryer
- Injection molding equipment
- injection molding hopper dryer
- Injection molding machine
- injection molding machine brand
- Injection Molding Machine Factory
- Injection Molding Machine Manufacture
- Injection molding machine manufacturer
- injection molding machine manufacturers
- Injection molding machine procurement
- injection molding machine robotic arm
- injection molding machine with a robot
- Injection molding machines
- injection molding material dehumidifying
- injection molding plant
- injection molding process
- Injection Molding Robot
- injection molding robot arm
- Injection molding robot automation
- Injection molding robotic arm
- injection molding robots
- injection molding whole plant
- injection moulding dryer
- Injection moulding machine
- injection moulding machines
- Injection Moulding Robots
- Injection Robot
- Injection robot arm
- Injection robot manufacturer
- Injection robot wholesale
- injection robots
- Intelligent Factory
- intelligent injection molding machines
- Intelligent Manufacturing
- intelligent mold temperature
- intelligent mold temperature controller
- Intelligent mould temperature controller
- intelligent whole plant solution
- InterPlas Thailand 2025
- Introducing Injection Robot
- It is the best choice for drying large quantities of material at once. Cabinetmakers use these machines because they are fast
- Large flow water type mold temperature controller
- large injection molding machine
- large injection molding machines
- Learn what industrial automation and robotics is
- linear robot
- linear robots
- low speed sound-proof granulator
- machine plastic molding
- make sure to add some! Improvements (2) Keyphrase in introduction: Your keyphrase or its synonyms appear in the first paragraph of the copy
- manipulator machine
- manufacturing
- Manufacturing Innovation
- medical grade injection molding machines
- Medical Injection Molding
- medical injection molding machine
- medical injection molding machines
- micro injection molding machine
- middle speed granulator
- Mini CNC machine manufacturers.
- mobile cover making machine
- Mold Temperature Control System
- mold temperature controller
- mold temperature controllers
- molding machine
- molding material Dehumidifying System
- mould temperature control system
- mould temperature controller
- mould temperature controller
- mould temperature controllers
- New electric injection molding machine
- Nitrogen Dryer
- nitrogen dryer manufacturer
- nitrogen dryer system manufacturer
- Oil type mold temperature controller
- Oil type mold temperature controllers
- open day
- optical component injection molding
- Optical-grade dehumidifying dryer
- Outbound links: No outbound links appear in this page. Add some! Images: No images appear on this page. Add some! Internal links: No internal links appear in this page
- packaging injection molding
- Packaging Solutions
- PET Preform injection molding
- phone case maker machine
- phone case making machine
- phone cover making machine
- PID Control Mold Temperature Controller
- plastic auto loader
- plastic bottle making machine
- plastic bottle manufacturing
- plastic bucket making machine
- plastic bucket manufacturing
- Plastic chair making machine
- plastic dryer for injection molding
- plastic forming equipment
- Plastic Granulator
- Plastic Granulators
- plastic hopper dryer
- plastic injection machine
- plastic injection machines
- plastic injection molding
- Plastic injection molding equipment
- Plastic injection molding machine
- Plastic Injection Molding Machines
- plastic injection moulding machine
- plastic injection moulding machines
- plastic injection robot
- plastic molding
- Plastic Molding Industry
- Plastic Molding machine
- plastic molding machine 1
- Plastic Molding Machines
- plastic molding press
- plastic moulding machine
- plastic phone case making machine
- plastic-molding machine
- powerful granulator
- Powerful Type Sound-Proof Granulator
- precision injection molding
- precision injection molding machines
- production of plastic seats
- pure water mould temperature controller
- Robot injection molding
- robot injection molding machine
- robot manufacturing companies
- Robotic arm for injection molding machine
- robotic injection molding machines
- robotics in injection molding
- SCARA robot
- SCARA robots
- Screw dosers
- Service-oriented manufacturing
- Servo Cylinder Robot
- servo driven robot
- Servo Driven Robots
- servo injection molding machine
- servo injection robots
- servo motor-driven linear robots
- servo-driven 3-axis robot
- Servo-driven injection molding machine
- Servo-Driven Robot
- Setup of injection machine
- Silicone Injection Molding Machine
- six-axis industrial robot
- Smart Manufacturing
- soundproof granulator
- Sprue Picker
- Stainless Hopper Dryer
- Stainless Hopper Dryers
- star club
- swing arm robot
- T1 Cartesian injection robot
- take-out robot
- take-out robots
- Thailand 4.0
- the choice between servo-driven robots and hydraulic robots will have a certain impact on efficiency
- the most popular injection molding machine
- the type of injection molding robot
- TIC2000 Control System
- TMII injection molding machine
- toggle clamp injection molding machine
- Toggle Hydraulic Injection Molding Machines
- toggle injection molding machine
- Top 10 brands of injection robots
- Topstar
- Topstar Electric Injection Molding Machine InterPlas Thailand 2025 Smart Manufacturing Thailand 4.0
- Topstar Engineering
- Topstar Industrial Robots
- Topstar injection molding intelligent
- Topstar Scara Robots
- Useful Injection molding machine
- Vertical machining centers
- volumetric type blender
- Washing Machine Case Molding Solution
- water chiller
- water chillers
- water distributor
- water type mold temperature controller
- Water Type MoldTemperature Controller
- Water-Cooled Chillers
- Water-cooled Mold Temperature Controller
- water-type mold temperature controller
- Water-Type Mould Temperature Controllers
- We often face choices when performing injection molding. We will choose the type of injection molding machine
- wholesale of injection molding machines
- x carve CNC
- 热门查询 点击次数 展示 排名 topstar