How Can Servo Off Control Reduce Standby Energy Use During Production Interruptions?
2026/11/06 By le zhan
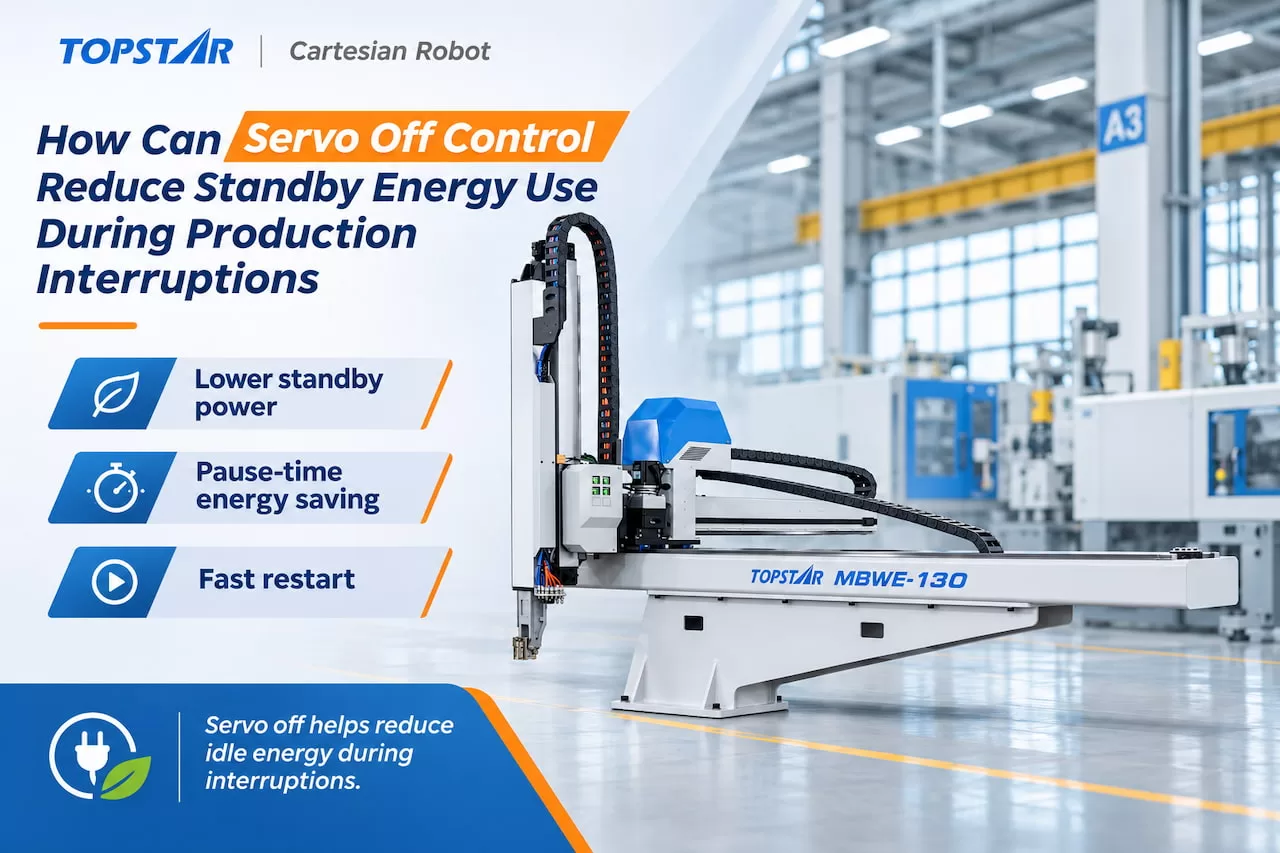
During injection molding, robots are not always operating; they may remain idle while waiting for the next molding cycle, material supply, or downstream equipment to become ready. However, even when the robotic arm is not moving, its servo drives may continue to consume power to maintain their operational state. To reduce this unnecessary standby energy consumption, Topstar has incorporated a Servo Off control function—when the robot is not required to operate, operators can cut power to the drive circuit directly via the teach pendant. Additionally, the company uses a 5-in-1 integrated servo drive that shares a single discharge braking resistor, improving energy efficiency by about 10% compared to standalone servo drive configurations. This design reduces overall energy consumption during both robot operation and production downtime.
Servo Off Control and the 5-in-1 Drive
Injection molding robots may still consume power even when not moving. To address this, we have adopted two approaches to reduce energy consumption:
First, optimizing power sharing and management among multiple servo axes;
Second, cutting off power to unnecessary servo motors during production downtime.
The combination of the 5-in-1 integrated servo drive and the Servo Off Control function effectively resolves this issue.
How Does the 5-in-1 Driver Improve Energy Efficiency?
Traditional injection molding robots typically equip each motor with a separate servo driver. Topstar’s 5-in-1 architecture integrates the control functions of five servo motors into a single drive system, thereby reducing the need for multiple independent drive units.
This integrated configuration requires only one braking resistor (used to dissipate regenerative energy), eliminating the need to configure a separate braking resistor for each driver. This not only simplifies the electrical layout but also reduces redundant hardware configurations. Data comparisons show this configuration achieves energy efficiency about 10% higher than traditional independent servo drive setups. Its advantages extend beyond simply reducing the number of drive components; the integrated architecture enables multi-axis coordination, supporting more precise synchronized motion and more efficient power management.
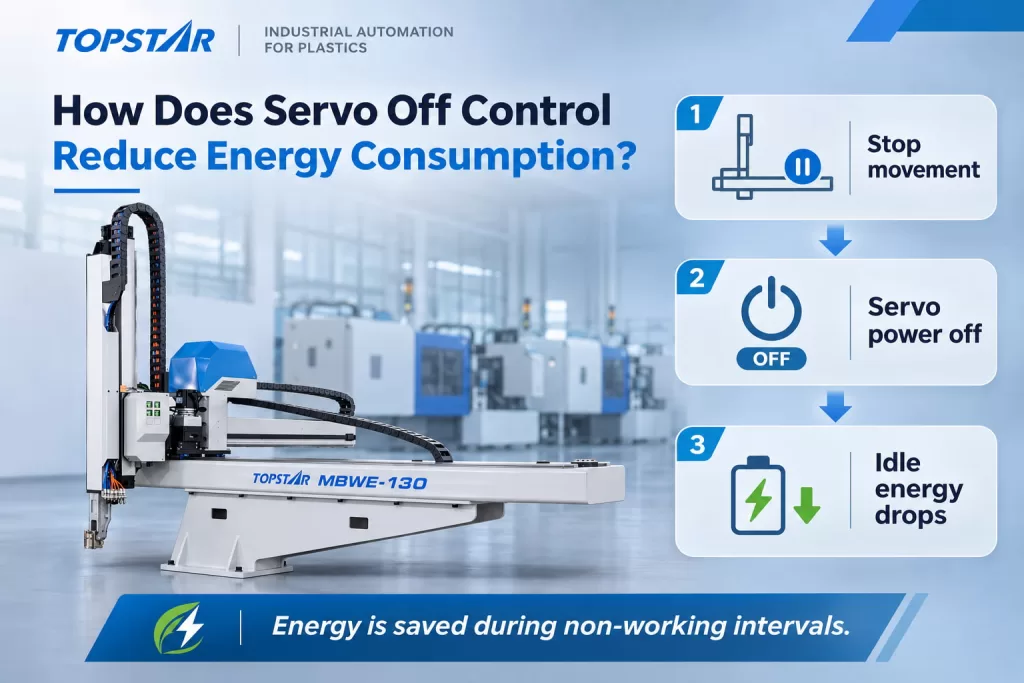
How Does Servo Off Control Reduce Energy Consumption?
When a Cartesian robot stops moving, its energy consumption does not necessarily drop to zero. If the servo system remains enabled, the servo drive’s electronic components may continue to consume standby power. Depending on the mechanical load and control mode, the servo motor may also require current to maintain its position or hold torque.
In addition, the robot controller, PLC, communication interfaces, and safety circuits may still receive power.
Servo Off control eliminates unnecessary energy consumption that occurs when operators keep the servo drive and motor systems powered on without requiring motion. Of course, operators do not need to shut down the entire robot. This way, the equipment can reduce unnecessary servo energy consumption without treating every production interruption as a full machine shutdown.
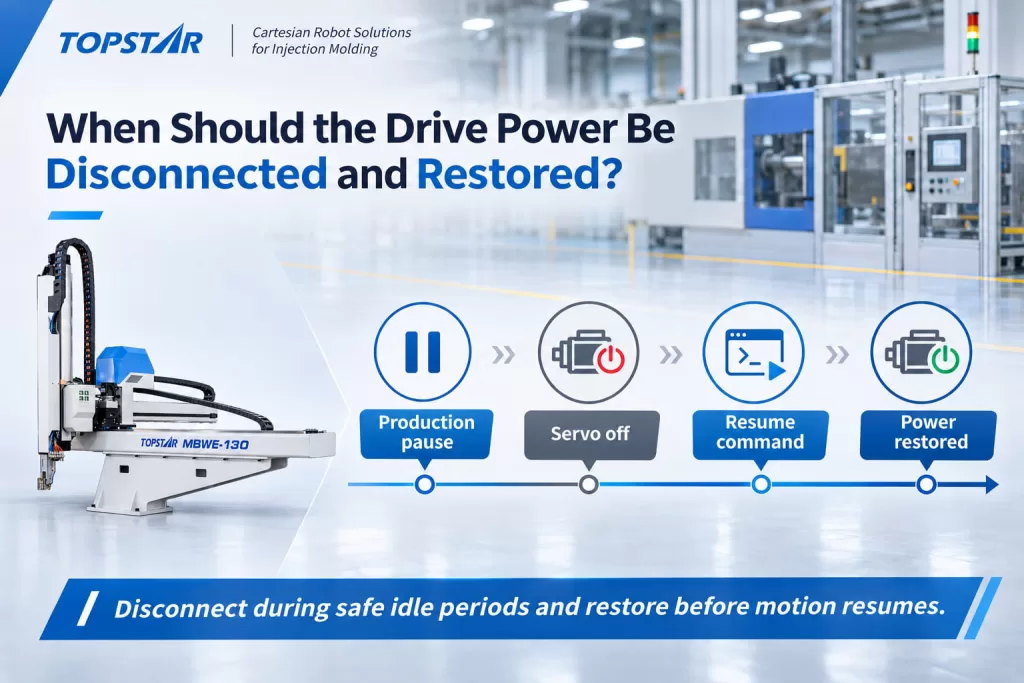
When Should the Drive Power Be Disconnected and Restored?
Disconnecting the servo drive power reduces unnecessary energy consumption, but operators must first ensure that the robot is in an appropriate standby state. Operators must securely clamp the workpiece, move the robot away from the mold area, and ensure that all axes can safely maintain or return to their positions. After restoring power, operators should also verify the robot’s position and operating status before resuming automated production.
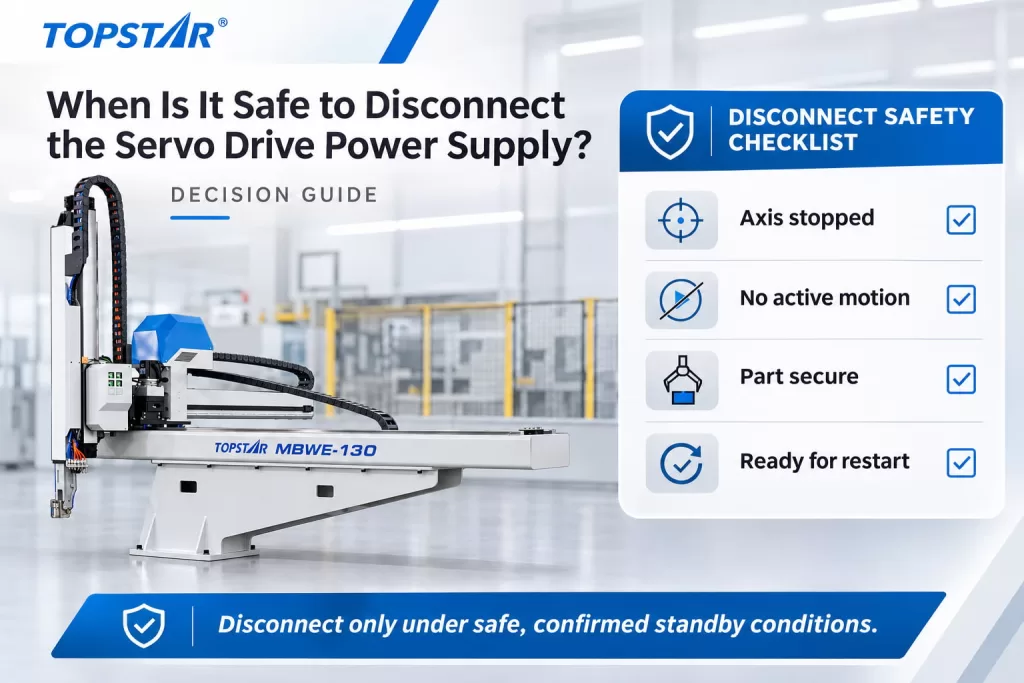
When Is It Safe to Disconnect the Servo Drive Power Supply?
The Servo Off control is best suited for planned production interruptions, i.e., when the robot is stationary and will not need to perform any actions for a short period.
Before disconnecting the drive power supply, operators should confirm the following three conditions:
- – Robot Position: All axes have completed their movements and returned to their designated safe standby positions.
- – Workpiece and Fixture Status: The robot does not grip a workpiece while it hangs unsupported, nor does it rely on real-time torque from the servo drive to maintain a load.
- – Equipment Coordination: The robot has exited the mold area, and the injection molding machine and peripheral equipment are all in a safe operating state.
If the interruption is brief and the robot needs to resume motion immediately or remain in a specific position, it may be more appropriate to keep the servo drive powered on.
For extended downtime, using the Servo Off function can reduce unnecessary motor power consumption and energy waste.
Note that Servo Off is an energy-saving standby feature and cannot replace complete electrical isolation. Before performing maintenance on the robot, maintenance personnel must still strictly adhere to the factory’s power isolation and “Lockout/Tagout” procedures.
Which axes should be checked after a restart?
After restoring power to the servo drive, operators should verify each robot axis’s position and operational status before resuming automated production.
Pay special attention to the vertical axis, as gravity may cause it to move when the servo drive loses power. Operators should confirm that the mechanical holding device is secure and reliable, and that the position feedback signal is valid. Other axes also require verification:
– Vertical axes: Check height, hold status, and reference positions.
– Lateral axes: Confirm that the robotic arm is in the expected horizontal position.
– Longitudinal axes: Verify pick-up and transfer positions.
– Rotational or attitude axes: For five-axis configurations, check the workpiece orientation and rotational reference points.
Note: Never assume the axes retain valid reference positions just because servo power has been restored.
Cut Off Unnecessary Power Supply to Reduce Standby Energy Consumption
The Servo Off control function cuts off unnecessary power to the servo drives and motors when the robot is not moving, reducing standby energy consumption. Combined with 5-in-1 integrated drive technology and simplified braking resistor configuration, this solution offers a more energy-efficient option for injection molding automation.
For production facilities, the key is to use this feature during appropriate production downtime and ensure that the robot can safely maintain or return to its operating position when production resumes. This approach reduces standby power consumption while balancing equipment safety and production continuity, achieving an ideal equilibrium.
TRENDING POSTS
- TOPS DAY 2026: Turning Industrial AI into Real-World Impact 2026/11/06
- Breaking Through the Full Scene-to-AI Link! Topstar Industrial Data Collection Matrix Achieves Major Technical Breakthro 2026/11/06
- TOPSTAR Selected in “Forbes China AI Top 50” and Wins “2026 Embodied AI Industry Benchmark Award” 2026/11/06
- Topstar Achieves ISO 13849 Functional Safety Certification for Robotics 2026/11/06
HOT TOPIC
- .ervo motor-driven linear robots
- •
- 1.0 guangdong topstar technology co. ltd
- 1.0 topstar china
- 1.0 topstar robot
- 11
- 160℃ mold temperature controller
- 170 ton injection molding machine
- 2
- 21
- 220-ton injection molding machine
- 23
- 260 ton injection molding machine
- 3 axis robot
- 3 axis robots
- 3 in 1 Compact Dehumidifying Dryer
- 3-axis robot
- 3-axis robots
- 39
- 4 axis robot
- 4-axis SCARA robot
- 41
- 460T injection molding machine
- 5-axis CNC machine
- 62
- 90 ton injection molding machine
- accuracy
- Air Chillers
- air-cooled chillers
- all electric injection molding machine
- all electric injection molding machines
- all-electric injection molding machine
- All-electric injection molding machines
- and overall production quality. Therefore
- AP-RubberPlas
- auto cooling system
- auto loader
- Auto Loaders
- automated injection molding machine
- Automation changed engineering
- automation of injection molding robots
- automotive parts injection molding
- Auxiliary Equipment
- auxiliary machine
- Bench Injection Molding Machine
- cabinet dryer
- Cabinet dryer manufacturers
- Cabinet dryers
- cartesian coordinate robot
- Cartesian Coordinate Robots
- Cartesian injection robot
- Cartesian robot
- Central Feeding System
- Central Feeding Systems
- chiller
- CNC Drilling Machine
- CNC Drilling Machines
- cnc engraving machine manufacturer
- cnc laser cutting machine manufacturer
- CNC machine
- CNC Machine Center
- CNC Machine for Sale
- CNC Machine Manufacturing
- CNC Machine Tool
- CNC machine tool product
- CNC Machining Center
- CNC wood carving machine
- Compact Dehumidifying Dryer
- Cooling system
- Cross-Walking Single Axis Servo Cylinder Robot
- Cross-Walking Single-Axis Servo Cylinder Robot
- Cross-Walking Three-Axis/Five-Axis Servo Driven Robot
- cross-walking three-axis/five-axis servo-driven robot
- Dehumidifier Dryer
- Dehumidifying Dryer
- dehumidifying dryers
- delta parallel robot
- Desktop Injection Molding Machine
- Desktop injection molding machines
- Desktop Molding Machine
- desktop plastic injection machine
- Desktop Plastic Injection Molding Machine
- detachable autoloader
- Digital Transformation
- direct clamp injection molding machine
- Direct clamp injection molding machines
- Dosing & mixing system
- Drilling Centers
- Drying and dehumidification system
- drying and dehumidifying equipment
- Drying and Dehumidifying System
- drying system
- effective and efficient. Cabinet dryers are also used in other industries where large quantities of material need to be dried
- efficient injection molding machine
- elbow hydraulic injection molding machines
- electric injection molding machine
- electric injection molding machines
- energy-efficient injection molding robot
- energy-efficient water chiller
- energy-efficient water chillers
- energy-saving injection molding machine
- etc. Among injection molding robots
- exhibition
- features of CNC machine
- Feeding And Conveying System
- Five Axis Machine Center
- Flexible Production Line
- Fully automatic injection molding machine
- Gathering Topstar
- giant injection molding machine
- GMU-600 5-Axis Machining Center
- Granulating & Recycling System
- granulator machine
- gravimetric blender
- Heavy duty injection molding machine
- Heavy-Duty Take-Out Robot
- High-precision electric molding machines
- high-precision plastic molding machines
- high-speed all electric injection molding machine
- high-speed electric injection molding machine
- High-Speed Packaging Injection Molding
- Honeycomb rotor dehumidifier
- hopper dryer
- Hopper Dryers
- horizontal injection molding machine
- Horizontal Injection Molding Machines
- Horizontal Injection Moulding Machine
- Horizontal Mixer manufacturer
- How The CNC Machine Works
- hybrid injection molding machine
- hydraulic injection molding machine
- Hydraulic Injection Molding Machines
- in this article
- Industrial AI
- Industrial Automation
- Industrial robot
- Industrial Robot Chinese brand
- industrial robot parts
- industrial robot supplier
- Industrial robots
- Industry Chain
- Injection Manipulator
- injection manipulator robot
- injection mold machines
- Injection molding
- Injection molding automation
- Injection Molding Automation Solution
- injection molding dryer
- Injection molding equipment
- injection molding hopper dryer
- Injection molding machine
- injection molding machine brand
- Injection Molding Machine Factory
- Injection Molding Machine Manufacture
- Injection molding machine manufacturer
- injection molding machine manufacturers
- Injection molding machine procurement
- injection molding machine robotic arm
- injection molding machine with a robot
- Injection molding machines
- injection molding material dehumidifying
- injection molding plant
- injection molding process
- Injection Molding Robot
- injection molding robot arm
- Injection molding robot automation
- Injection molding robotic arm
- injection molding robots
- injection molding whole plant
- injection moulding dryer
- Injection moulding machine
- injection moulding machines
- Injection Moulding Robots
- Injection Robot
- Injection robot arm
- Injection robot manufacturer
- Injection robot wholesale
- injection robots
- Intelligent Factory
- intelligent injection molding machines
- Intelligent Manufacturing
- intelligent mold temperature
- intelligent mold temperature controller
- Intelligent mould temperature controller
- intelligent whole plant solution
- InterPlas Thailand 2025
- Introducing Injection Robot
- It is the best choice for drying large quantities of material at once. Cabinetmakers use these machines because they are fast
- Large flow water type mold temperature controller
- large injection molding machine
- large injection molding machines
- Learn what industrial automation and robotics is
- linear robot
- linear robots
- low speed sound-proof granulator
- machine plastic molding
- make sure to add some! Improvements (2) Keyphrase in introduction: Your keyphrase or its synonyms appear in the first paragraph of the copy
- manipulator machine
- manufacturing
- Manufacturing Innovation
- medical grade injection molding machines
- Medical Injection Molding
- medical injection molding machine
- medical injection molding machines
- micro injection molding machine
- middle speed granulator
- Mini CNC machine manufacturers.
- mobile cover making machine
- Mold Temperature Control System
- mold temperature controller
- mold temperature controllers
- molding machine
- molding material Dehumidifying System
- mould temperature control system
- mould temperature controller
- mould temperature controller
- mould temperature controllers
- New electric injection molding machine
- Nitrogen Dryer
- nitrogen dryer manufacturer
- nitrogen dryer system manufacturer
- Oil type mold temperature controller
- Oil type mold temperature controllers
- open day
- optical component injection molding
- Optical-grade dehumidifying dryer
- Outbound links: No outbound links appear in this page. Add some! Images: No images appear on this page. Add some! Internal links: No internal links appear in this page
- packaging injection molding
- Packaging Solutions
- PET Preform injection molding
- phone case maker machine
- phone case making machine
- phone cover making machine
- PID Control Mold Temperature Controller
- plastic auto loader
- plastic bottle making machine
- plastic bottle manufacturing
- plastic bucket making machine
- plastic bucket manufacturing
- Plastic chair making machine
- plastic dryer for injection molding
- plastic forming equipment
- Plastic Granulator
- Plastic Granulators
- plastic hopper dryer
- plastic injection machine
- plastic injection machines
- plastic injection molding
- Plastic injection molding equipment
- Plastic injection molding machine
- Plastic Injection Molding Machines
- plastic injection moulding machine
- plastic injection moulding machines
- plastic injection robot
- plastic molding
- Plastic Molding Industry
- Plastic Molding machine
- plastic molding machine 1
- Plastic Molding Machines
- plastic molding press
- plastic moulding machine
- plastic phone case making machine
- plastic-molding machine
- powerful granulator
- Powerful Type Sound-Proof Granulator
- precision injection molding
- precision injection molding machines
- production of plastic seats
- pure water mould temperature controller
- Robot injection molding
- robot injection molding machine
- robot manufacturing companies
- Robotic arm for injection molding machine
- robotic injection molding machines
- robotics in injection molding
- SCARA robot
- SCARA robots
- Screw dosers
- Service-oriented manufacturing
- Servo Cylinder Robot
- servo driven robot
- Servo Driven Robots
- servo injection molding machine
- servo injection robots
- servo motor-driven linear robots
- servo-driven 3-axis robot
- Servo-driven injection molding machine
- Servo-Driven Robot
- Setup of injection machine
- Silicone Injection Molding Machine
- six-axis industrial robot
- Smart Manufacturing
- soundproof granulator
- Sprue Picker
- Stainless Hopper Dryer
- Stainless Hopper Dryers
- star club
- swing arm robot
- T1 Cartesian injection robot
- take-out robot
- take-out robots
- Thailand 4.0
- the choice between servo-driven robots and hydraulic robots will have a certain impact on efficiency
- the most popular injection molding machine
- the type of injection molding robot
- TIC2000 Control System
- TMII injection molding machine
- toggle clamp injection molding machine
- Toggle Hydraulic Injection Molding Machines
- toggle injection molding machine
- Top 10 brands of injection robots
- Topstar
- Topstar Electric Injection Molding Machine InterPlas Thailand 2025 Smart Manufacturing Thailand 4.0
- Topstar Engineering
- Topstar Industrial Robots
- Topstar injection molding intelligent
- Topstar Scara Robots
- Useful Injection molding machine
- Vertical machining centers
- volumetric type blender
- Washing Machine Case Molding Solution
- water chiller
- water chillers
- water distributor
- water type mold temperature controller
- Water Type MoldTemperature Controller
- Water-Cooled Chillers
- Water-cooled Mold Temperature Controller
- water-type mold temperature controller
- Water-Type Mould Temperature Controllers
- We often face choices when performing injection molding. We will choose the type of injection molding machine
- wholesale of injection molding machines
- x carve CNC
- 热门查询 点击次数 展示 排名 topstar