How Do Ejector-Following Control and Servo Torque Detection Protect Ejector Pins?
2026/11/09 By le zhan
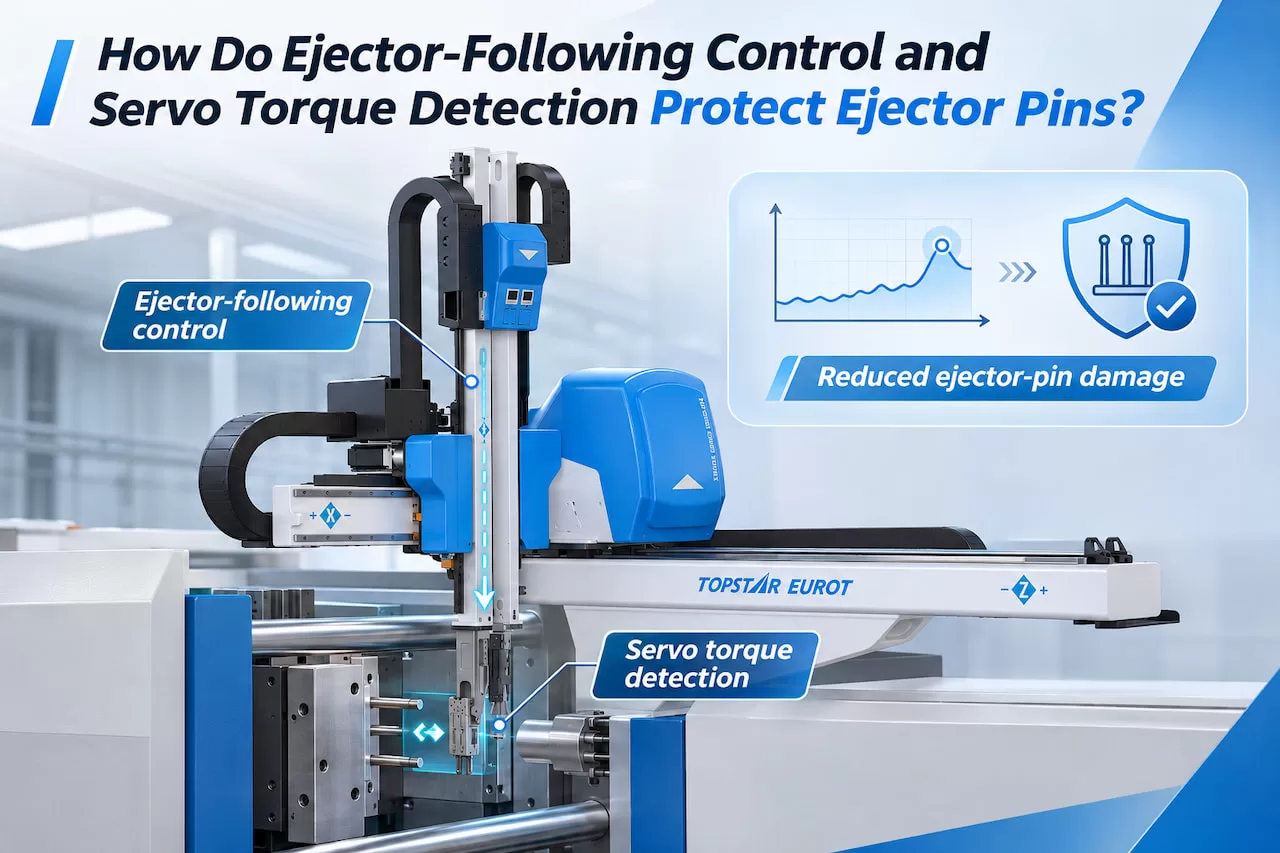
During part removal on an injection molding robot, poor coordination between the robotic arm, mold ejector pins, and the part-removal sequence can cause collisions, leading to bent ejector pins, mold damage, or product deformation. Topstar effectively mitigates these risks through its “Ejector-Following Control” and “Servo Torque Detection” features, enabling the robotic arm to respond flexibly to external forces rather than mechanically executing preset movements. By adjusting joint torque in real time, monitoring abnormal loads, and adding an interlock between the ejector pins and the core-pulling mechanism, Topstar’s injection molding robots ensure reliable part removal while protecting critical mold components.
Ejector-Following Control: How Does a Torque-Based Protection Mechanism Prevent Mechanical Collisions?
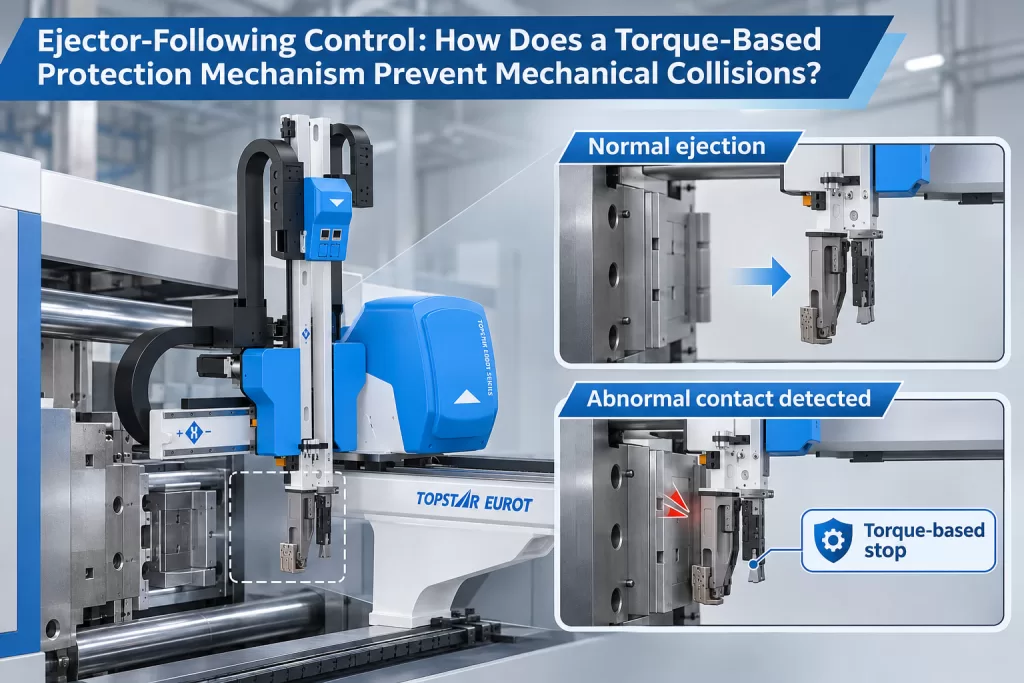
During automated part removal, the injection molding robot must enter the mold cavity and coordinate its movements with the mold ejector pins. If positioning deviations or unexpected contact occur and the robot continues along its original trajectory, it can cause excessive mechanical stress. With flexible joint control and servo torque monitoring, the injection molding robot can detect abnormal contact and adjust its response before excessive force damages the mold or ejector pins.
How Does the Flexible Motion Enabled by Ejector-following Control Protect the Ejector Pins?
Traditional injection molding robot motion strictly follows a preset trajectory. If the robotic arm contacts the ejector pins due to positioning errors or timing discrepancies, it may continue applying force instead of adapting to the contact situation.
Ejector-following control technology enables the robotic arm to respond flexibly to external forces by adjusting joint torque in real time. Specifically, when the robotic arm comes into contact with the ejector pin, the system monitors the resulting torque; once the detected force exceeds a preset threshold, the system activates the “flexible floating” function, allowing the robotic arm to adjust accordingly based on the contact situation rather than forcibly executing the originally planned motion.
This controlled motion cushions unexpected contact and reduces forces transmitted to the ejector pins and the mold.
Its key advantages include:
- Reducing the risk of collisions during mold insertion and part removal.
- Preventing excessive mechanical stress on the ejector pins.
- Reducing the likelihood of mold damage caused by positioning deviations.
- Facilitating installation, commissioning, and maintenance through smooth, manual movement.
How Does Servo Torque Sensing Detect Abnormal Contact?
Flexible motion protects contact; equally important is the robot’s ability to detect abnormal mechanical loads during commissioning and production.
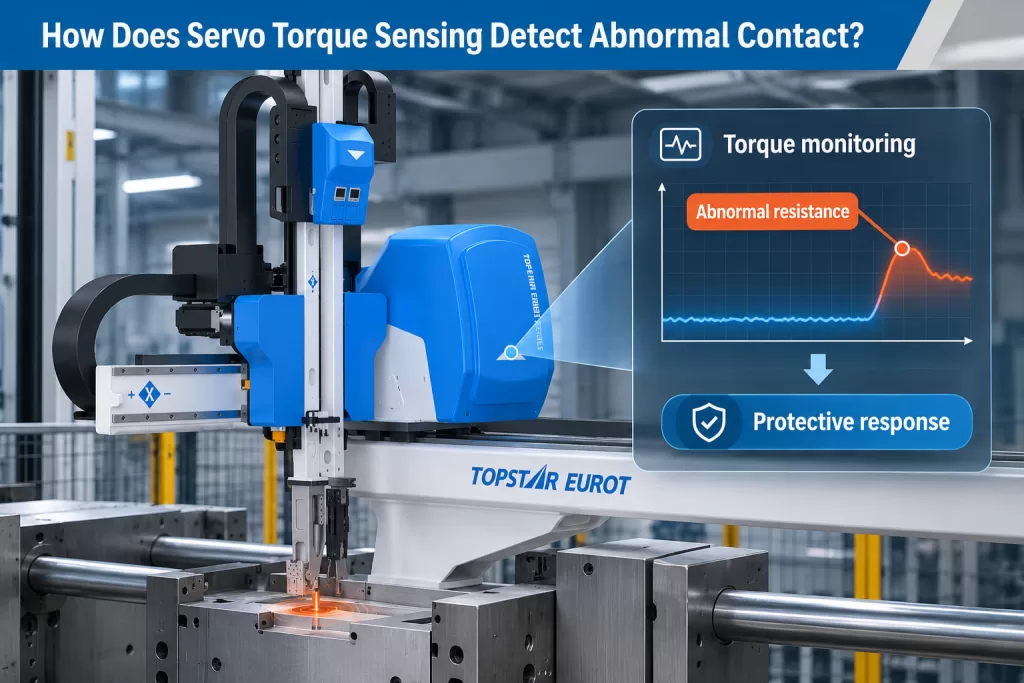
Therefore, Topstar has integrated servo torque sensing technology into its Cartesian robots to identify abnormal contact conditions by monitoring changes in servo torque. For example, if the operator sets an incorrect robot position, or if the gripper approaches the mold at an unexpected angle, the robotic arm may encounter resistance that exceeds the normal operating range.
When the detected torque exceeds a preset threshold, the protection mechanism triggers a flexible response, thereby reducing excessive forces acting on the gripper, mold ejector pins, and other mechanical components.
Servo torque detection is particularly effective in the following scenarios:
- During initial robot installation and mold debugging.
- When adjusting grasping and removal positions.
- During automated operations where positioning deviations may occur.
- During repetitive high-speed movements requiring precise stopping positions.
Excessive robot torque can damage molds, ejector pins, and molded products, increasing scrap rates and causing unplanned downtime.
How Does Machine Interlocking Prevent Damage to Ejection and Core-Pulling Mechanisms?
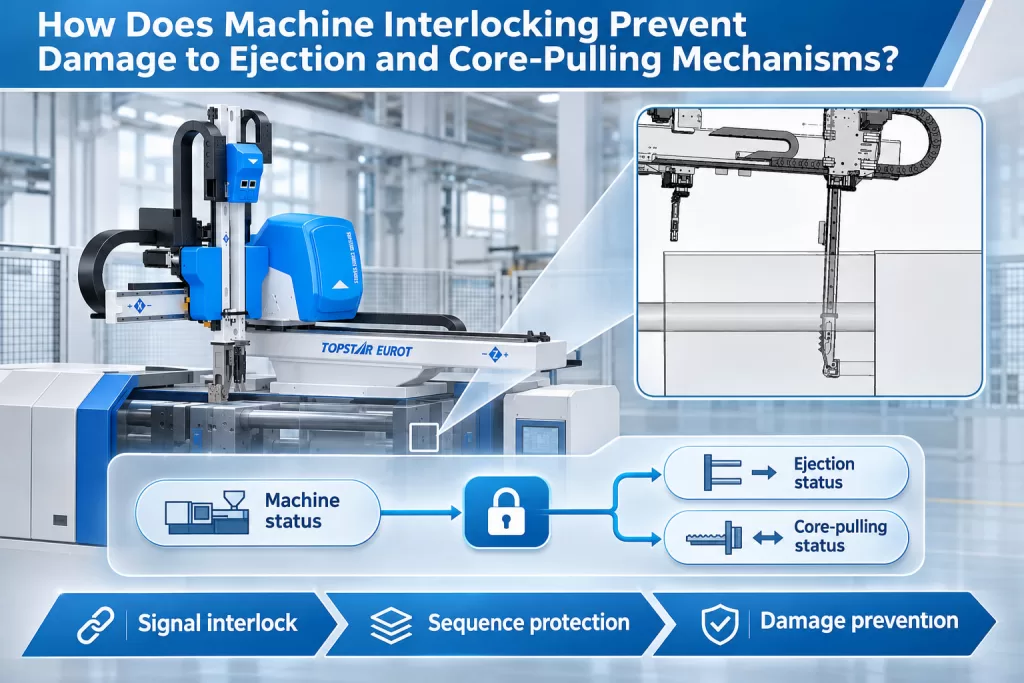
Torque protection alone cannot resolve all ejection-related issues. Some failures occur because operations between the injection molding machine and the Cartesian injection molding robot are improperly sequenced. For example, the mold ejection mechanism may retract before the robot has fully removed the product, or the core-pulling action may begin while the part is still engaged with the mold. Topstar ensures all mechanical actions follow the correct production sequence through signal coordination between the robot and the injection molding machine, along with precise control of ejection and core-pulling motions, effectively mitigating the risks above.
How Does Ejection and Core-Pulling Interlocking Protect the Mold?
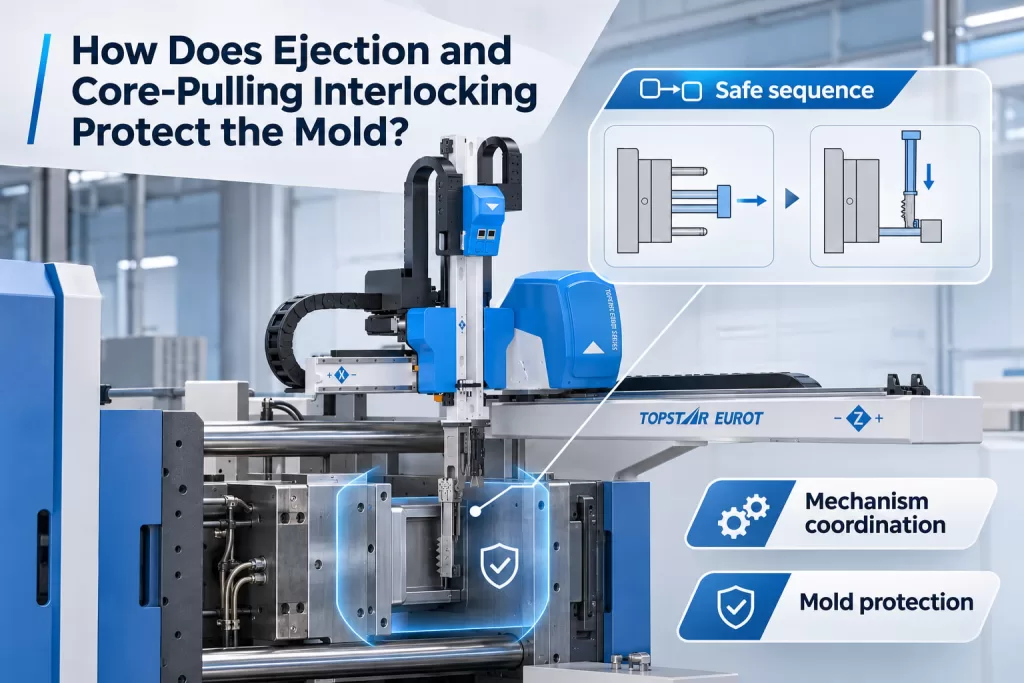
During demolding, the robot, ejector pins, and core-pulling mechanism must operate in the correct sequence. Topstar’s injection molding robots support ejection synchronization (linking ejection forward and reverse movements), keeping their actions highly synchronized with the injection molding machine.
If the molded part has not yet been successfully removed, the corresponding ejection or core-pulling actions should not be executed prematurely. This effectively prevents the ejection pins from squeezing residual material, avoids robot-mold collisions, and stops the robot from crushing the part during demolding.
The principle is simple: before executing the next mechanical action, first confirm that the preceding operation has been completed. This mechanism adds a layer of sequence protection beyond torque-based collision protection.
How Do These Protective Functions Work Together?
These protective technologies are designed for different stages of the product removal process. Their effectiveness comes from coordinated cooperation across multiple functions, rather than relying on a single protective measure.
The specific protection process is as follows:
Before removal: Before the robot enters the mold area, it first verifies that the mold is open and the ejection mechanism is in the correct state. During contact: When abnormal contact exceeds a preset threshold, the ejector pin follow-up control function adjusts the joint torque and activates flexible floating mode.
When abnormal load occurs: The servo torque detection function identifies excessive resistance and helps prevent the continued application of destructive forces.
After product removal: The interlock function between the ejector pins and the core-pulling mechanism verifies that the operational sequence meets requirements, ensuring the process is error-free before the next mold cycle.
During debugging, engineers should verify parameters such as torque thresholds, robot entry positions, ejector pin signals, and product removal confirmation based on the actual mold and fixture configurations.
Overall, the ejector-following control enables compliant motion, “servo torque detection” identifies abnormal contact, and the interlock function between the ejector pins and the core-pull mechanism prevents conflicts between mechanical movements. Together, these functions protect the ejector pins, reduce the risk of mold collisions, and ensure reliable injection molding production.(For more information on Topstar’s injection molding robot technologies, please visit: Injection Molding Robot Technology)
TRENDING POSTS
- TOPS DAY 2026: Turning Industrial AI into Real-World Impact 2026/11/09
- Breaking Through the Full Scene-to-AI Link! Topstar Industrial Data Collection Matrix Achieves Major Technical Breakthro 2026/11/09
- TOPSTAR Selected in “Forbes China AI Top 50” and Wins “2026 Embodied AI Industry Benchmark Award” 2026/11/09
- Topstar Achieves ISO 13849 Functional Safety Certification for Robotics 2026/11/09
HOT TOPIC
- .ervo motor-driven linear robots
- •
- 1.0 guangdong topstar technology co. ltd
- 1.0 topstar china
- 1.0 topstar robot
- 11
- 160℃ mold temperature controller
- 170 ton injection molding machine
- 2
- 21
- 220-ton injection molding machine
- 23
- 260 ton injection molding machine
- 3 axis robot
- 3 axis robots
- 3 in 1 Compact Dehumidifying Dryer
- 3-axis robot
- 3-axis robots
- 39
- 4 axis robot
- 4-axis SCARA robot
- 41
- 460T injection molding machine
- 5-axis CNC machine
- 62
- 90 ton injection molding machine
- accuracy
- Air Chillers
- air-cooled chillers
- all electric injection molding machine
- all electric injection molding machines
- all-electric injection molding machine
- All-electric injection molding machines
- and overall production quality. Therefore
- AP-RubberPlas
- auto cooling system
- auto loader
- Auto Loaders
- automated injection molding machine
- Automation changed engineering
- automation of injection molding robots
- automotive parts injection molding
- Auxiliary Equipment
- auxiliary machine
- Bench Injection Molding Machine
- cabinet dryer
- Cabinet dryer manufacturers
- Cabinet dryers
- cartesian coordinate robot
- Cartesian Coordinate Robots
- Cartesian injection robot
- Cartesian robot
- Central Feeding System
- Central Feeding Systems
- chiller
- CNC Drilling Machine
- CNC Drilling Machines
- cnc engraving machine manufacturer
- cnc laser cutting machine manufacturer
- CNC machine
- CNC Machine Center
- CNC Machine for Sale
- CNC Machine Manufacturing
- CNC Machine Tool
- CNC machine tool product
- CNC Machining Center
- CNC wood carving machine
- Compact Dehumidifying Dryer
- Cooling system
- Cross-Walking Single Axis Servo Cylinder Robot
- Cross-Walking Single-Axis Servo Cylinder Robot
- Cross-Walking Three-Axis/Five-Axis Servo Driven Robot
- cross-walking three-axis/five-axis servo-driven robot
- Dehumidifier Dryer
- Dehumidifying Dryer
- dehumidifying dryers
- delta parallel robot
- Desktop Injection Molding Machine
- Desktop injection molding machines
- Desktop Molding Machine
- desktop plastic injection machine
- Desktop Plastic Injection Molding Machine
- detachable autoloader
- Digital Transformation
- direct clamp injection molding machine
- Direct clamp injection molding machines
- Dosing & mixing system
- Drilling Centers
- Drying and dehumidification system
- drying and dehumidifying equipment
- Drying and Dehumidifying System
- drying system
- effective and efficient. Cabinet dryers are also used in other industries where large quantities of material need to be dried
- efficient injection molding machine
- elbow hydraulic injection molding machines
- electric injection molding machine
- electric injection molding machines
- energy-efficient injection molding robot
- energy-efficient water chiller
- energy-efficient water chillers
- energy-saving injection molding machine
- etc. Among injection molding robots
- exhibition
- features of CNC machine
- Feeding And Conveying System
- Five Axis Machine Center
- Flexible Production Line
- Fully automatic injection molding machine
- Gathering Topstar
- giant injection molding machine
- GMU-600 5-Axis Machining Center
- Granulating & Recycling System
- granulator machine
- gravimetric blender
- Heavy duty injection molding machine
- Heavy-Duty Take-Out Robot
- High-precision electric molding machines
- high-precision plastic molding machines
- high-speed all electric injection molding machine
- high-speed electric injection molding machine
- High-Speed Packaging Injection Molding
- Honeycomb rotor dehumidifier
- hopper dryer
- Hopper Dryers
- horizontal injection molding machine
- Horizontal Injection Molding Machines
- Horizontal Injection Moulding Machine
- Horizontal Mixer manufacturer
- How The CNC Machine Works
- hybrid injection molding machine
- hydraulic injection molding machine
- Hydraulic Injection Molding Machines
- in this article
- Industrial AI
- Industrial Automation
- Industrial robot
- Industrial Robot Chinese brand
- industrial robot parts
- industrial robot supplier
- Industrial robots
- Industry Chain
- Injection Manipulator
- injection manipulator robot
- injection mold machines
- Injection molding
- Injection molding automation
- Injection Molding Automation Solution
- injection molding dryer
- Injection molding equipment
- injection molding hopper dryer
- Injection molding machine
- injection molding machine brand
- Injection Molding Machine Factory
- Injection Molding Machine Manufacture
- Injection molding machine manufacturer
- injection molding machine manufacturers
- Injection molding machine procurement
- injection molding machine robotic arm
- injection molding machine with a robot
- Injection molding machines
- injection molding material dehumidifying
- injection molding plant
- injection molding process
- Injection Molding Robot
- injection molding robot arm
- Injection molding robot automation
- Injection molding robotic arm
- injection molding robots
- injection molding whole plant
- injection moulding dryer
- Injection moulding machine
- injection moulding machines
- Injection Moulding Robots
- Injection Robot
- Injection robot arm
- Injection robot manufacturer
- Injection robot wholesale
- injection robots
- Intelligent Factory
- intelligent injection molding machines
- Intelligent Manufacturing
- intelligent mold temperature
- intelligent mold temperature controller
- Intelligent mould temperature controller
- intelligent whole plant solution
- InterPlas Thailand 2025
- Introducing Injection Robot
- It is the best choice for drying large quantities of material at once. Cabinetmakers use these machines because they are fast
- Large flow water type mold temperature controller
- large injection molding machine
- large injection molding machines
- Learn what industrial automation and robotics is
- linear robot
- linear robots
- low speed sound-proof granulator
- machine plastic molding
- make sure to add some! Improvements (2) Keyphrase in introduction: Your keyphrase or its synonyms appear in the first paragraph of the copy
- manipulator machine
- manufacturing
- Manufacturing Innovation
- medical grade injection molding machines
- Medical Injection Molding
- medical injection molding machine
- medical injection molding machines
- micro injection molding machine
- middle speed granulator
- Mini CNC machine manufacturers.
- mobile cover making machine
- Mold Temperature Control System
- mold temperature controller
- mold temperature controllers
- molding machine
- molding material Dehumidifying System
- mould temperature control system
- mould temperature controller
- mould temperature controller
- mould temperature controllers
- New electric injection molding machine
- Nitrogen Dryer
- nitrogen dryer manufacturer
- nitrogen dryer system manufacturer
- Oil type mold temperature controller
- Oil type mold temperature controllers
- open day
- optical component injection molding
- Optical-grade dehumidifying dryer
- Outbound links: No outbound links appear in this page. Add some! Images: No images appear on this page. Add some! Internal links: No internal links appear in this page
- packaging injection molding
- Packaging Solutions
- PET Preform injection molding
- phone case maker machine
- phone case making machine
- phone cover making machine
- PID Control Mold Temperature Controller
- plastic auto loader
- plastic bottle making machine
- plastic bottle manufacturing
- plastic bucket making machine
- plastic bucket manufacturing
- Plastic chair making machine
- plastic dryer for injection molding
- plastic forming equipment
- Plastic Granulator
- Plastic Granulators
- plastic hopper dryer
- plastic injection machine
- plastic injection machines
- plastic injection molding
- Plastic injection molding equipment
- Plastic injection molding machine
- Plastic Injection Molding Machines
- plastic injection moulding machine
- plastic injection moulding machines
- plastic injection robot
- plastic molding
- Plastic Molding Industry
- Plastic Molding machine
- plastic molding machine 1
- Plastic Molding Machines
- plastic molding press
- plastic moulding machine
- plastic phone case making machine
- plastic-molding machine
- powerful granulator
- Powerful Type Sound-Proof Granulator
- precision injection molding
- precision injection molding machines
- production of plastic seats
- pure water mould temperature controller
- Robot injection molding
- robot injection molding machine
- robot manufacturing companies
- Robotic arm for injection molding machine
- robotic injection molding machines
- robotics in injection molding
- SCARA robot
- SCARA robots
- Screw dosers
- Service-oriented manufacturing
- Servo Cylinder Robot
- servo driven robot
- Servo Driven Robots
- servo injection molding machine
- servo injection robots
- servo motor-driven linear robots
- servo-driven 3-axis robot
- Servo-driven injection molding machine
- Servo-Driven Robot
- Setup of injection machine
- Silicone Injection Molding Machine
- six-axis industrial robot
- Smart Manufacturing
- soundproof granulator
- Sprue Picker
- Stainless Hopper Dryer
- Stainless Hopper Dryers
- star club
- swing arm robot
- T1 Cartesian injection robot
- take-out robot
- take-out robots
- Thailand 4.0
- the choice between servo-driven robots and hydraulic robots will have a certain impact on efficiency
- the most popular injection molding machine
- the type of injection molding robot
- TIC2000 Control System
- TMII injection molding machine
- toggle clamp injection molding machine
- Toggle Hydraulic Injection Molding Machines
- toggle injection molding machine
- Top 10 brands of injection robots
- Topstar
- Topstar Electric Injection Molding Machine InterPlas Thailand 2025 Smart Manufacturing Thailand 4.0
- Topstar Engineering
- Topstar Industrial Robots
- Topstar injection molding intelligent
- Topstar Scara Robots
- Useful Injection molding machine
- Vertical machining centers
- volumetric type blender
- Washing Machine Case Molding Solution
- water chiller
- water chillers
- water distributor
- water type mold temperature controller
- Water Type MoldTemperature Controller
- Water-Cooled Chillers
- Water-cooled Mold Temperature Controller
- water-type mold temperature controller
- Water-Type Mould Temperature Controllers
- We often face choices when performing injection molding. We will choose the type of injection molding machine
- wholesale of injection molding machines
- x carve CNC
- 热门查询 点击次数 展示 排名 topstar